

Description
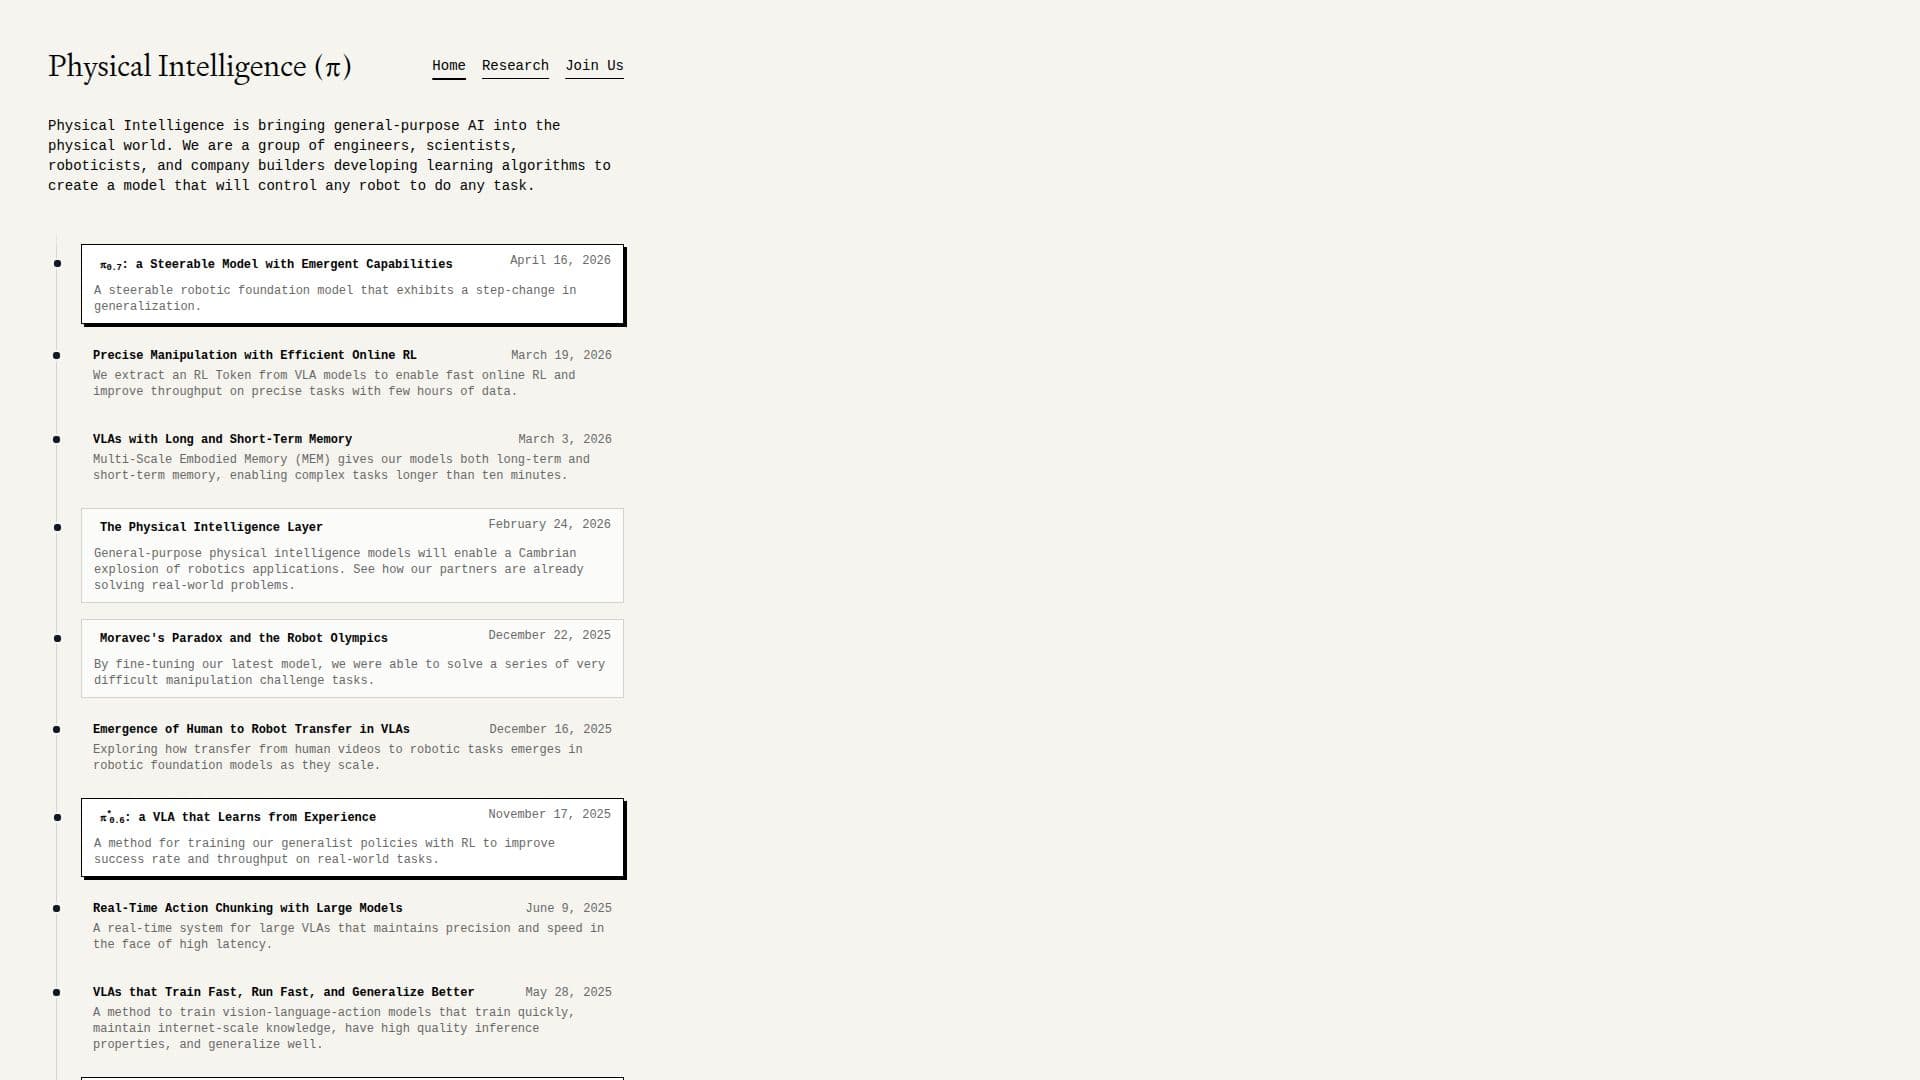
Physical Intelligence, styled π, is a robotics AI research and engineering company working on general-purpose models that control robots to perform physical tasks. Its team, described on its own site as engineers, scientists, roboticists and company builders, is trying to build a single model capable of controlling many different kinds of robots across many different tasks, rather than training a separate model for each robot or job.
Read More
The company publishes its work as a running series of research posts about its π family of vision-language-action (VLA) models. π0, released in October 2024, was the company's first generalist policy, combining large-scale multi-task and multi-robot data with a new network architecture; Physical Intelligence later open-sourced its weights and code, along with a companion action tokenizer called π0-FAST that the company says trains generalist policies about five times faster than earlier approaches. π0.5, published in April 2025, extended π0 toward open-world generalization, including controlling a mobile manipulator to tidy an unfamiliar kitchen or bedroom. Later posts describe π*0.6, trained with reinforcement learning to improve success rate and throughput on real-world tasks, and π0.7, described as a steerable model with emergent capabilities. A separate research line, Multi-Scale Embodied Memory (MEM), gives the models both long- and short-term memory so they can carry out tasks that run past ten minutes, and other posts cover real-time action chunking for large models and techniques for transferring skills learned from human videos to robots.
Physical Intelligence says its models are already used by partners solving real-world robotics problems, though its site does not name those partners and does not offer a public product, pricing page or account sign-up; access to the models beyond the open-sourced π0 release appears to run through direct partnerships rather than self-serve tools. The company is backed by investors including Bond, Jeff Bezos, Khosla Ventures, Lux Capital, OpenAI, Redpoint Ventures, Sequoia Capital, CapitalG and Thrive Capital. Readers who want the technical detail behind any of its models can find full write-ups, and in π0's case downloadable weights and code, on the company's research page.
- CategoryRobotics & AI Hardware
- Pricing ModelNot specified
- DeploymentCloud
- PlatformsRobots
Physical Intelligence (π)'s Core Features
π family of vision-language-action (VLA) models for general-purpose robot control
π0, the company's first open-sourced generalist robot policy, with released weights and code
π0.5, extending open-world generalization to new environments such as unfamiliar kitchens
π*0.6, trained with reinforcement learning to improve real-world task success and speed
π0.7, described as a steerable model with emergent capabilities
Multi-Scale Embodied Memory (MEM) for long- and short-term task memory beyond ten minutes
π0-FAST action tokenizer for faster generalist-policy training
Real-time action chunking for large vision-language-action models
Published research write-ups for every model release
How to use Physical Intelligence (π)?
Read the research: Browse the Physical Intelligence research page for write-ups on each π model release.
Get the open weights: Download the released π0 weights and code to run or fine-tune the model yourself.
Follow new releases: Check the research feed or the company's X account for new π model posts.
Explore a partnership: Contact the company directly through its site to discuss access beyond the open-sourced models, since there is no public sign-up.
Physical Intelligence (π)'s Use Cases
- Open-sourced robot policy
- Long-horizon task memory
- Robot foundation model research







