Description
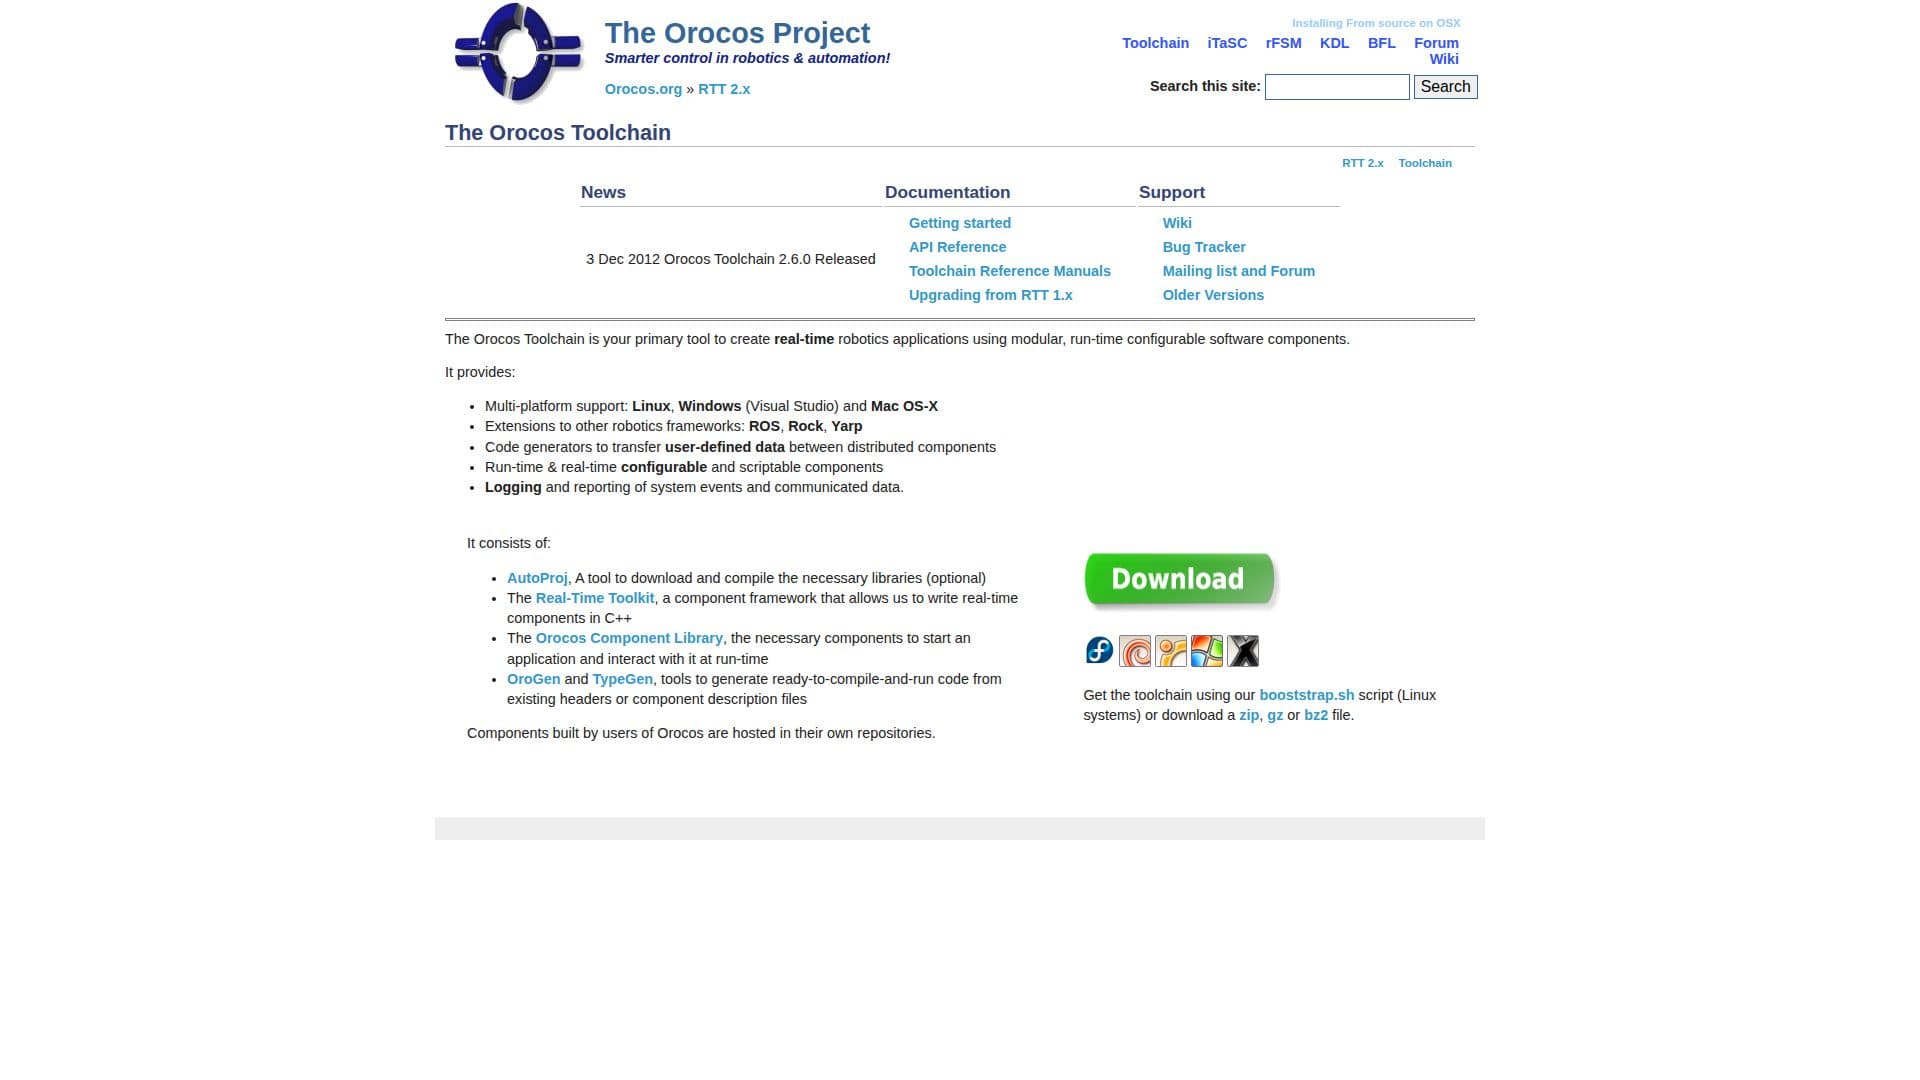
The Orocos Toolchain is a comprehensive suite designed for developing real-time robotics applications. It provides modular, run-time configurable software components that are essential for creating sophisticated robotics systems. The toolchain supports multiple platforms, including Linux, Windows, and Mac OS-X, making it versatile for various development environments.
Read More
One of the key features of the Orocos Toolchain is its ability to integrate with other robotics frameworks such as ROS, Rock, and Yarp. This integration allows developers to extend their applications beyond the Orocos ecosystem, leveraging the strengths of other frameworks. The toolchain includes code generators that facilitate the transfer of user-defined data between distributed components, ensuring efficient communication within the system.
The Orocos Toolchain consists of several components, including AutoProj, the Real-Time Toolkit, the Orocos Component Library, OroGen, and TypeGen. AutoProj is an optional tool for downloading and compiling necessary libraries. The Real-Time Toolkit is a component framework that enables developers to write real-time components in C++. The Orocos Component Library provides essential components for starting applications and interacting with them at run-time.
OroGen and TypeGen are tools for generating ready-to-compile-and-run code from existing headers or component description files. These tools simplify the process of creating components, making it accessible even to new users with minimal knowledge of the RTT API. The toolchain also offers logging and reporting capabilities for system events and communicated data, enhancing the monitoring and debugging processes.
Overall, the Orocos Toolchain is a valuable resource for developers in the robotics and automation industries, offering a robust set of tools for creating and managing real-time applications. Its multi-platform support and integration capabilities make it a versatile choice for various projects.
- CategoryRobotics & AI Hardware
- Pricing ModelOpen source
- DeploymentDynamic and static
- PlatformsLinux, Windows, Mac OS-X
Orocos Toolchain's Core Features
Multi-platform support: Linux, Windows, Mac OS-X
Integration with ROS, Rock, Yarp
Code generators for data transfer
Run-time configurable components
Real-time component framework
Orocos Component Library
Logging and reporting system
AutoProj for library management
How to use Orocos Toolchain?
Install: Use bootstrap.sh or download files
Configure: Set up libraries and components
Develop: Create components using OroGen
Deploy: Use DeploymentComponent for applications
Monitor: Utilize TaskBrowser for interaction
Orocos Toolchain's Use Cases
- Real-time robotics
- Framework integration
- Component creation
- System monitoring
- Multi-platform development