Description
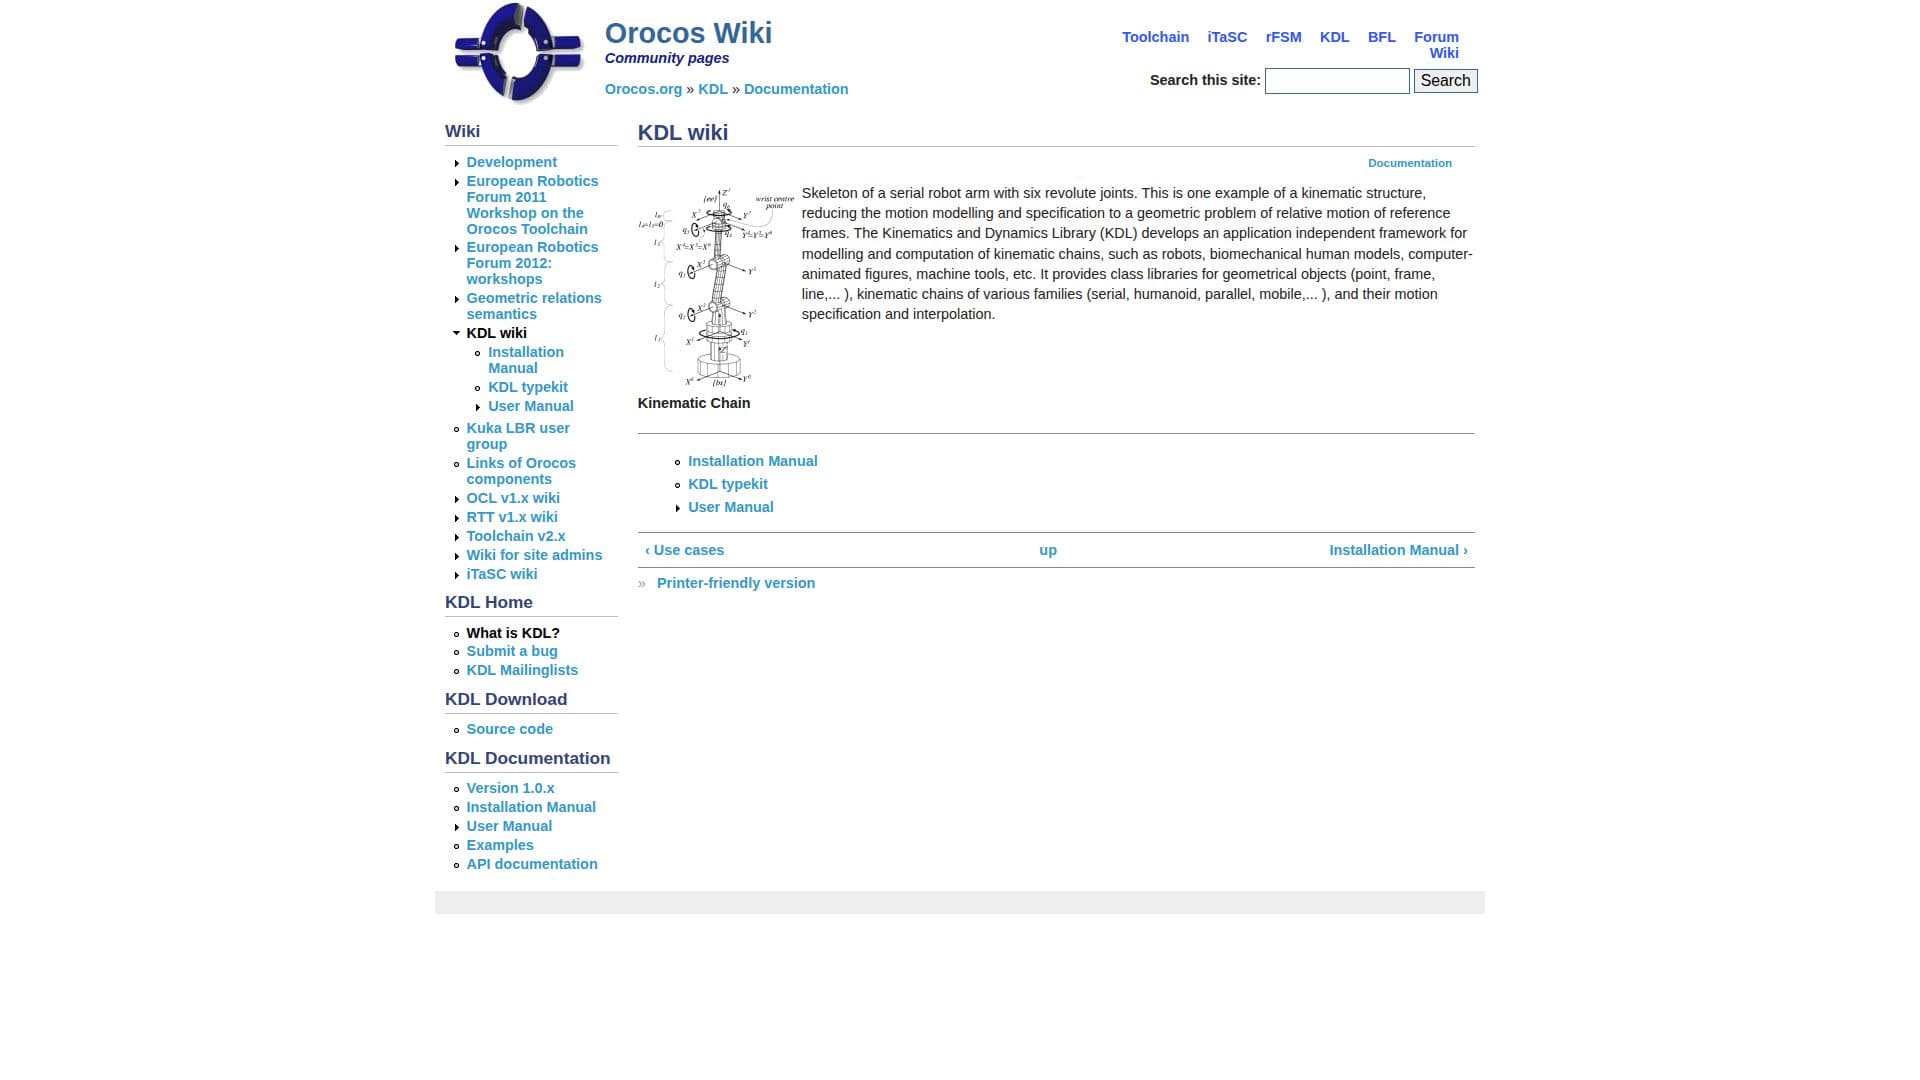
Orocos KDL, part of the Orocos Project, is a comprehensive framework designed for the modeling and computation of kinematic chains. It is application-independent, making it suitable for a wide range of uses including robotics, biomechanical human models, computer-animated figures, and machine tools. The library offers class libraries for geometrical objects such as points, frames, and lines, as well as kinematic chains of various families including serial, humanoid, parallel, and mobile.
The framework simplifies the motion modeling and specification process by reducing it to a geometric problem of relative motion of reference frames. This is particularly useful in robotics and automation, where precise control and movement are crucial. Orocos KDL supports the development of smarter control systems in these fields.
Users can access documentation and examples to better understand the framework's capabilities and applications. The community is encouraged to contribute by adding their own examples, fostering a collaborative environment for learning and development.
While the framework is powerful, users should be aware that it requires a solid understanding of kinematics and dynamics to fully leverage its capabilities. The Orocos Project provides resources and community support to assist users in overcoming these challenges.
Orocos KDL Framework's Core Features
Application-independent framework
Modeling of kinematic chains
Class libraries for geometrical objects
Support for various kinematic chain families
Geometric problem solving
Documentation and examples available
Community contributions encouraged
Smarter control in robotics and automation
How to use Orocos KDL Framework?
Configure: Set up kinematic chains
Use: Implement in robotics or animation
Optimise: Enhance control systems
Contribute: Add examples to the community
Orocos KDL Framework's Use Cases
- Robotics control
- Biomechanical modeling
- Animation
- Machine tools
- Kinematic research